Overview
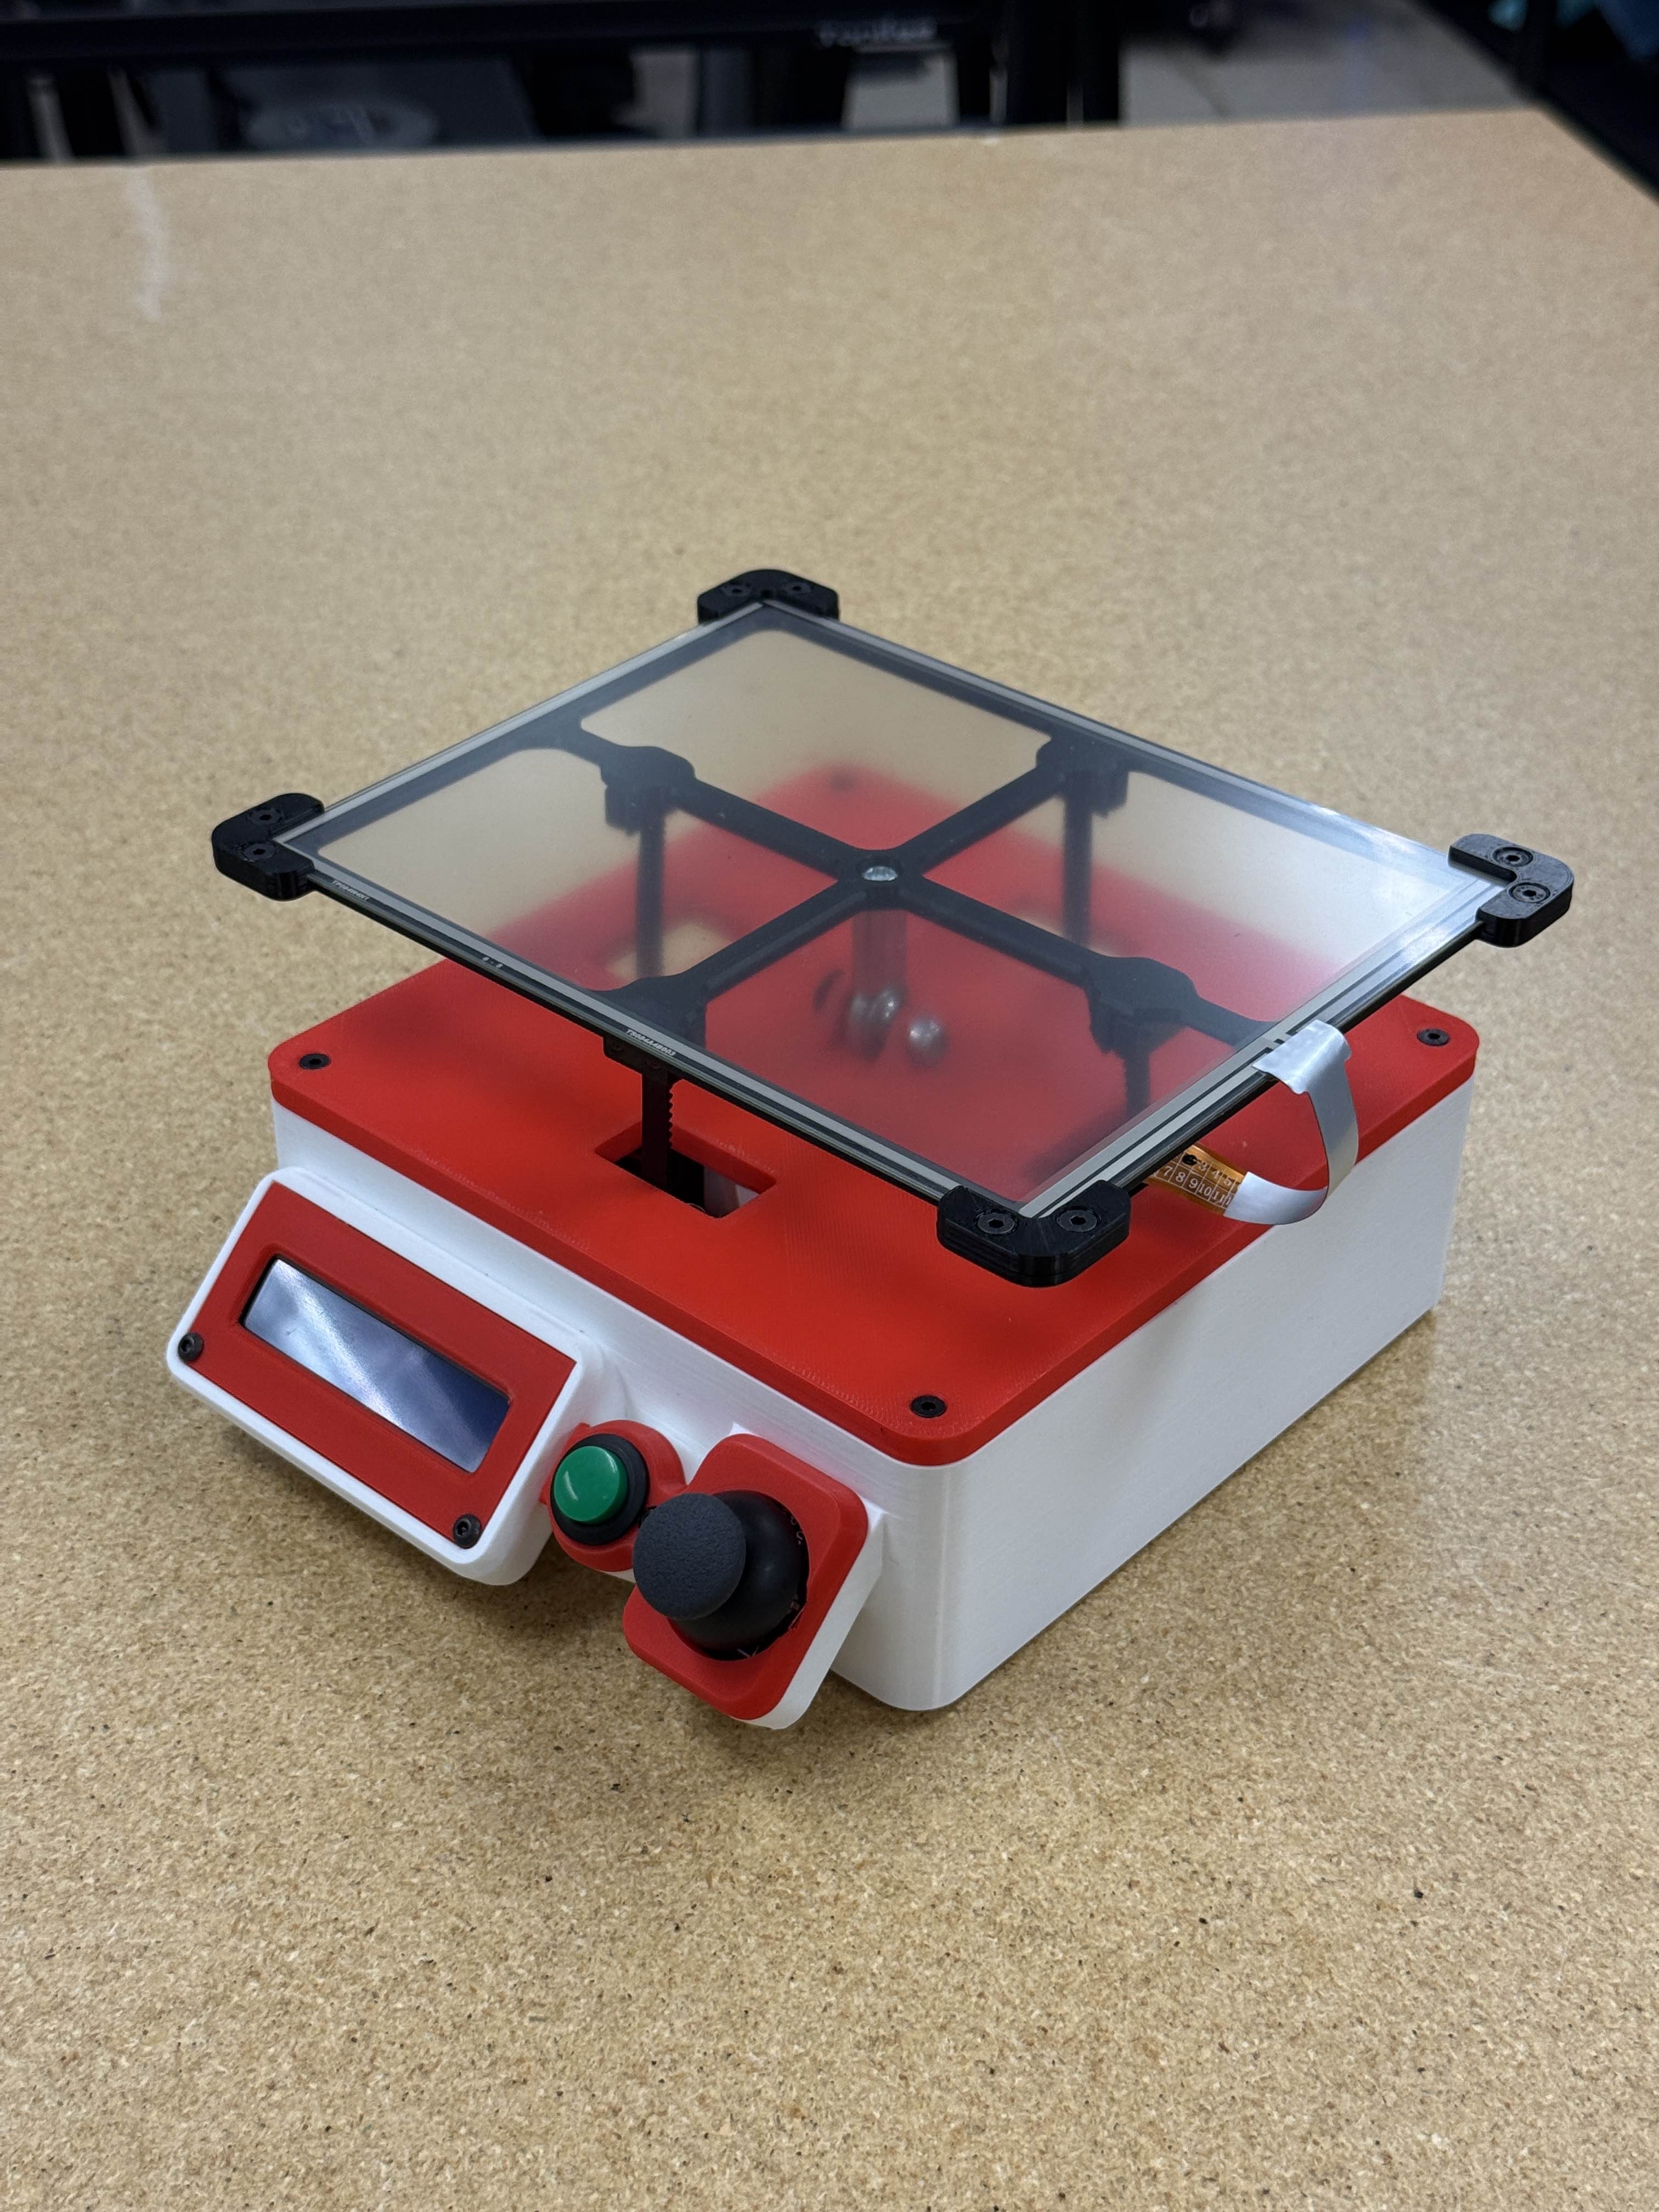
I’ve always been inspired by dynamically balancing robots, and I thought a ball balancer would be a good way to develop my electronics and embedded software skills. I built an initial version with belts that didn’t work, and I’m now redesigning it to be smaller, simpler, and more elegant.
Approach
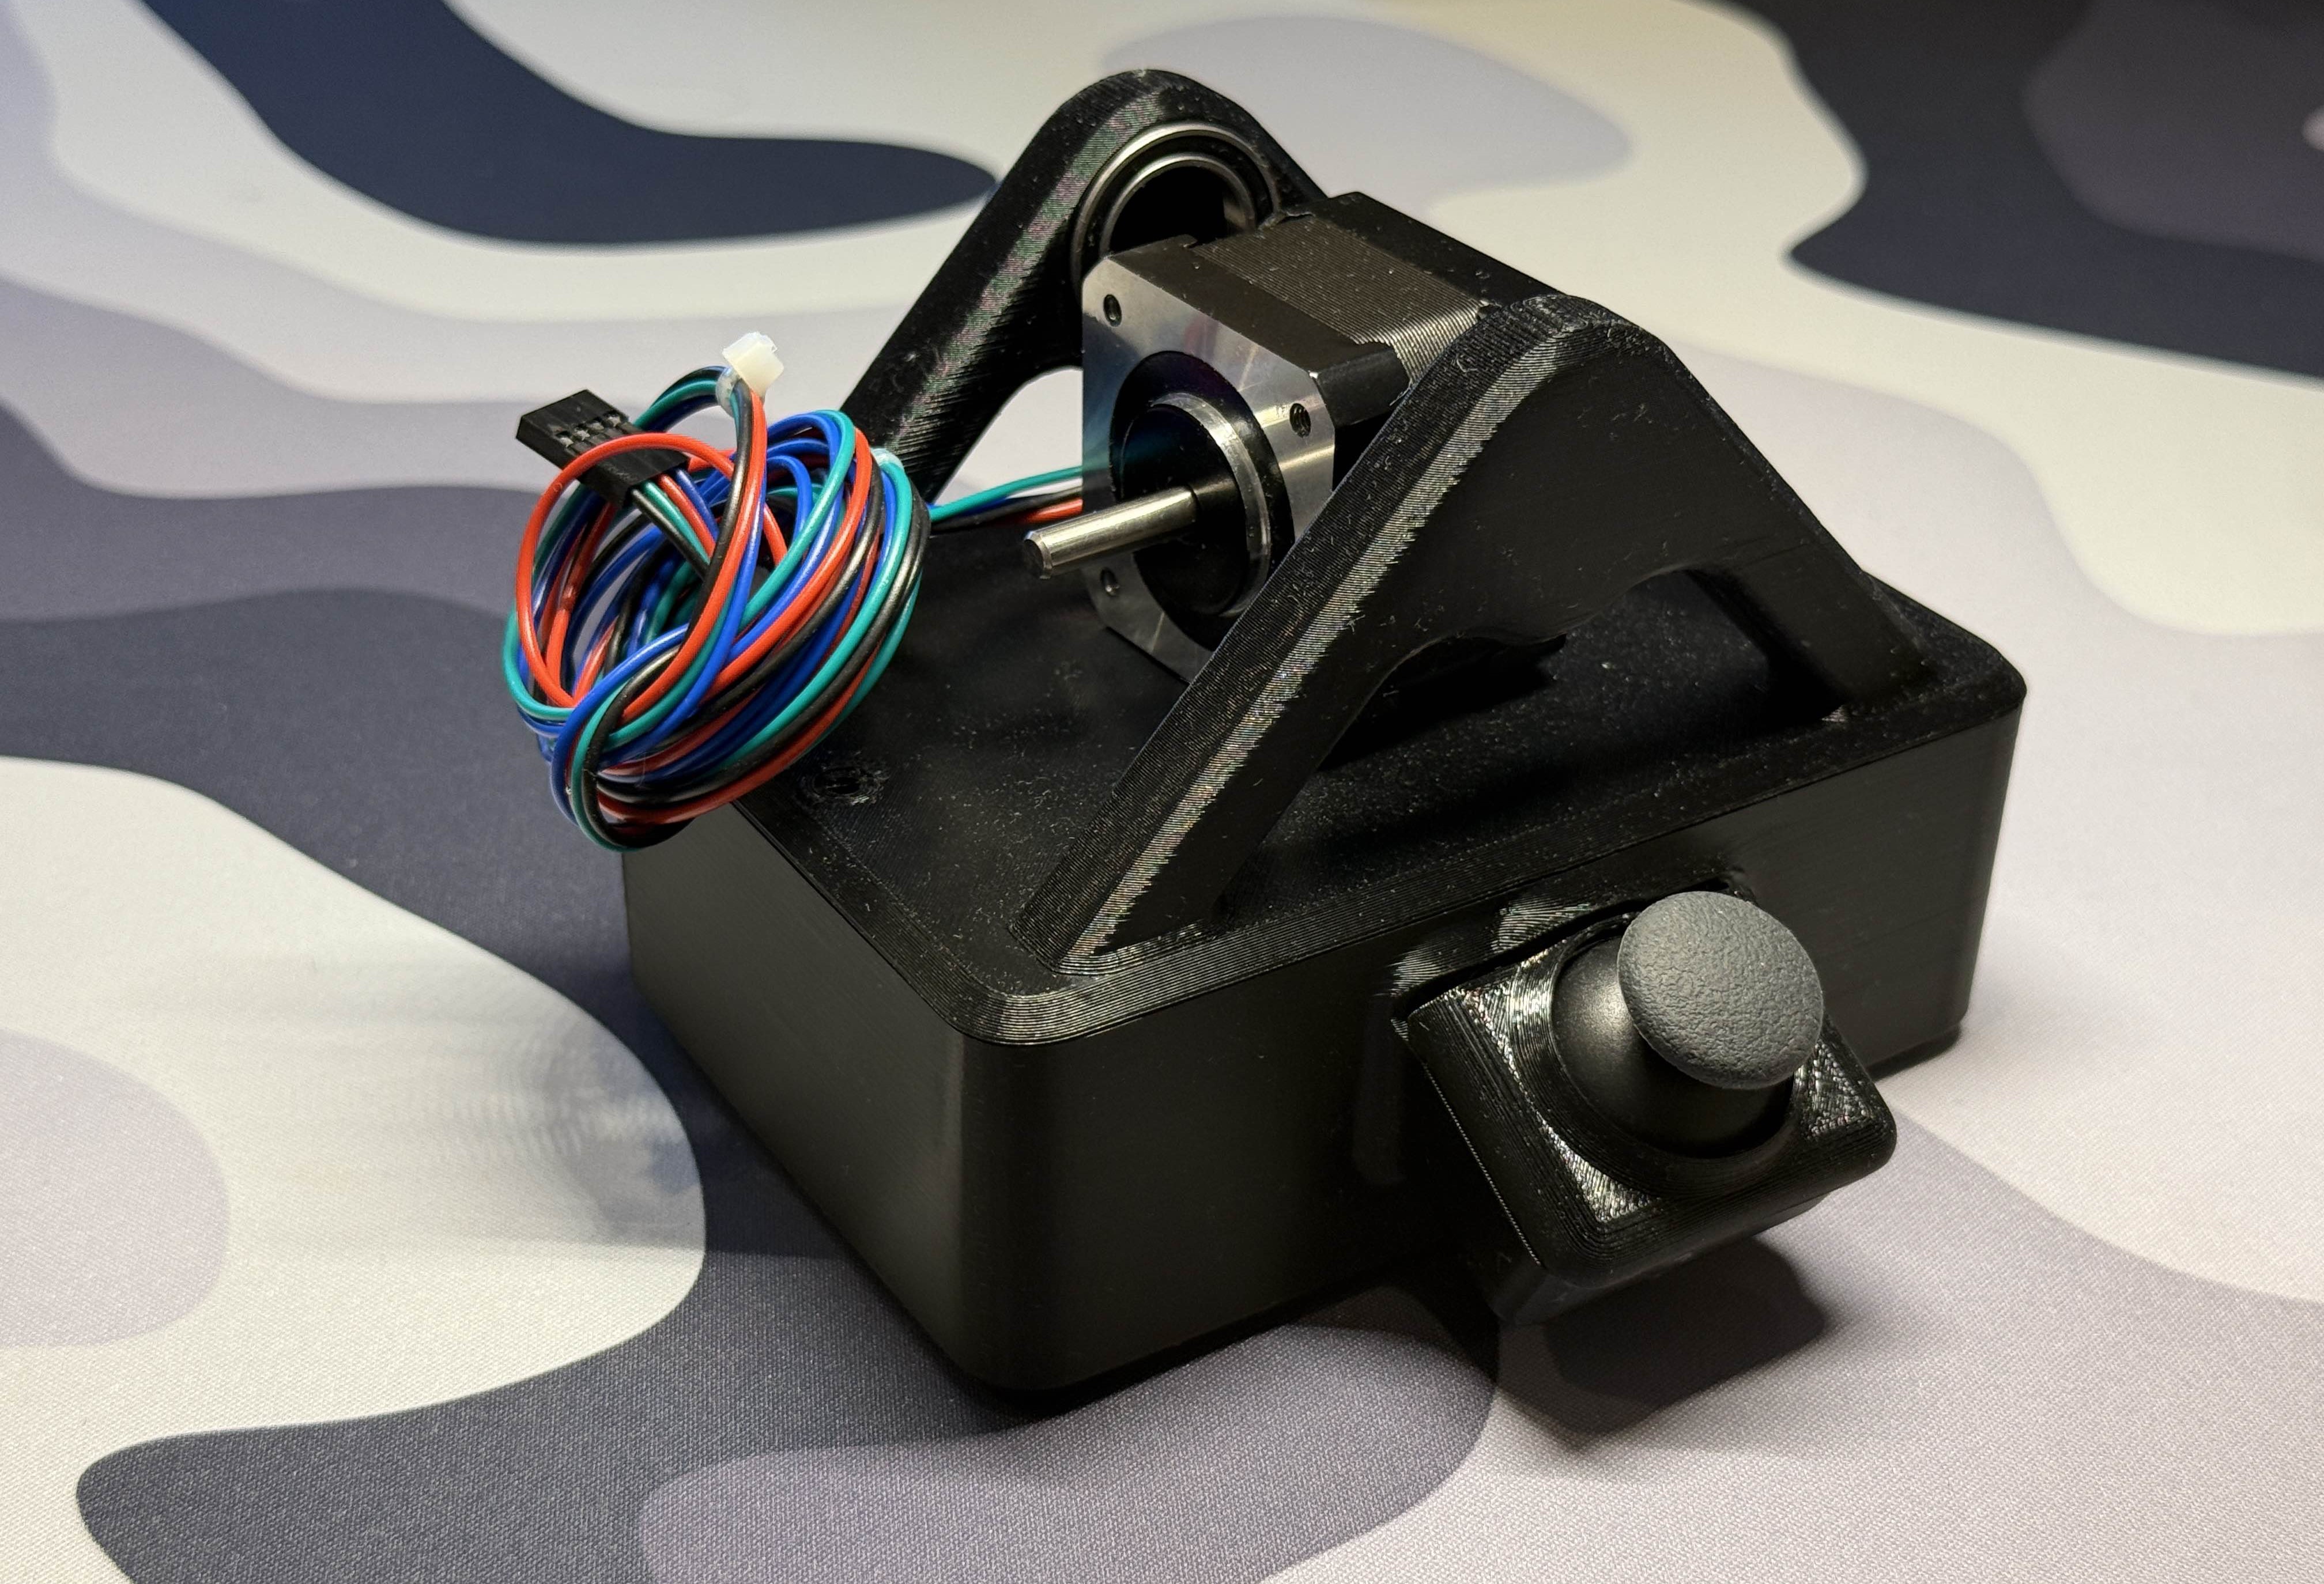
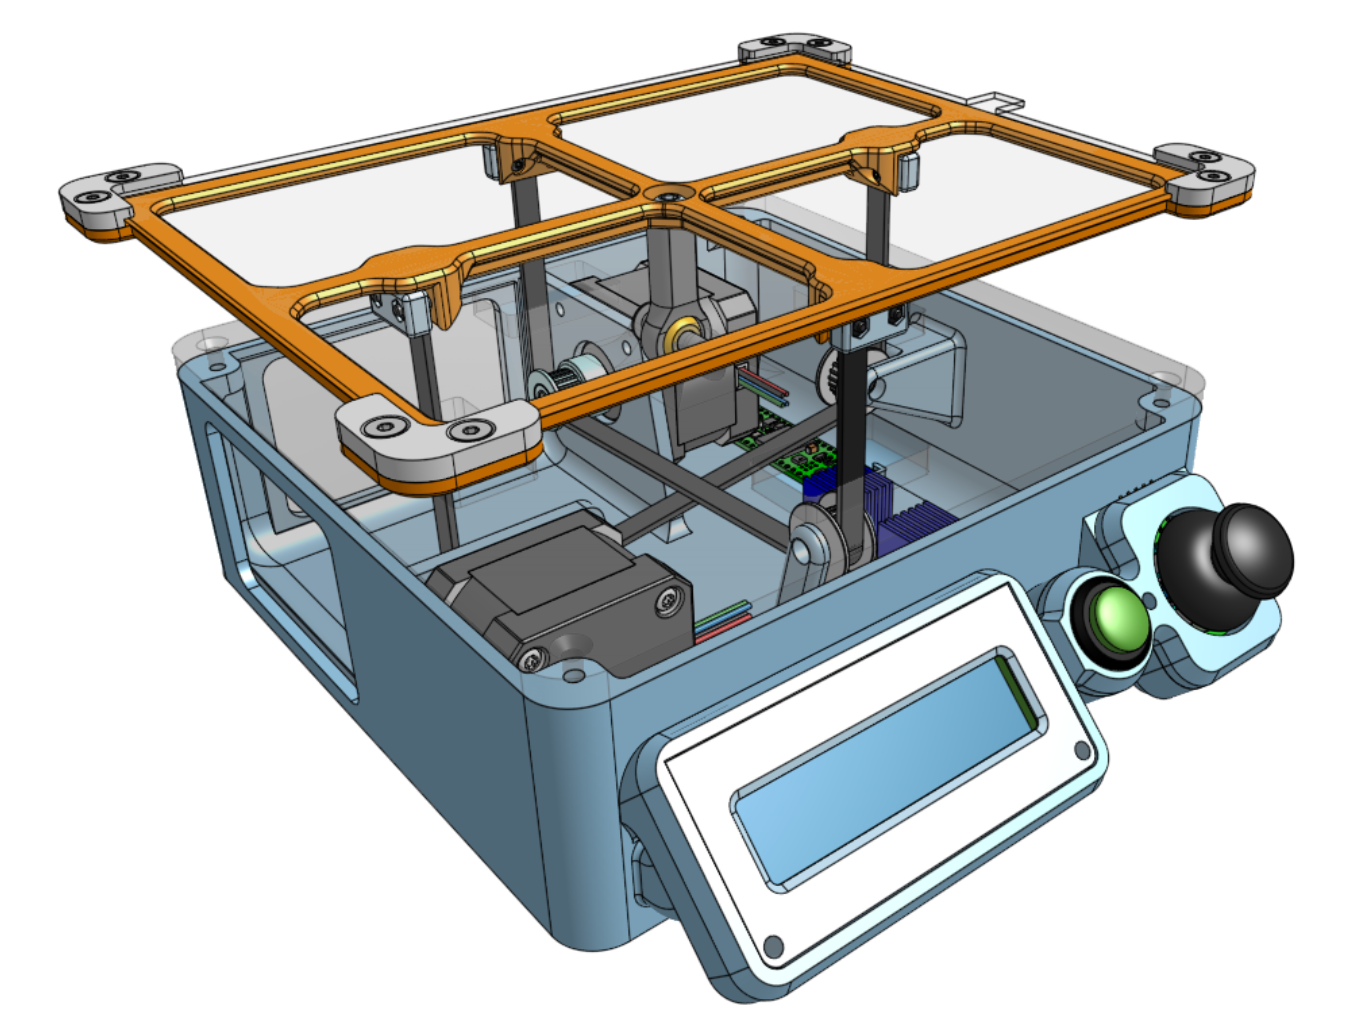
I set a rule for myself that I wouldn’t use the simple linkage mechanisms commonly seen in other ball balancers online. Instead, I wanted to explore a more unique way of actuating the platform. My first design used belts, but I quickly ran into problems because the belt could not translate laterally. I’m now using a combination of belts and linkages, similar to a pan-tilt gimbal, to create the two degrees of freedom needed to tilt the platform.